Whole-body control
A control approach that coordinates all joints of a robot together as one system.
When a humanoid reaches for a box on a low shelf, its legs, torso and arms must work together to keep the balance. Controlling each limb separately does not work for this, because moving the arm shifts the center of mass and the legs must respond.
Whole-body control is what makes a humanoid able to carry things, push a cart or open a heavy door while staying upright. In reviews, look for demos where the robot does a task with arms and legs together, not just walking and waving separately.
Related terms
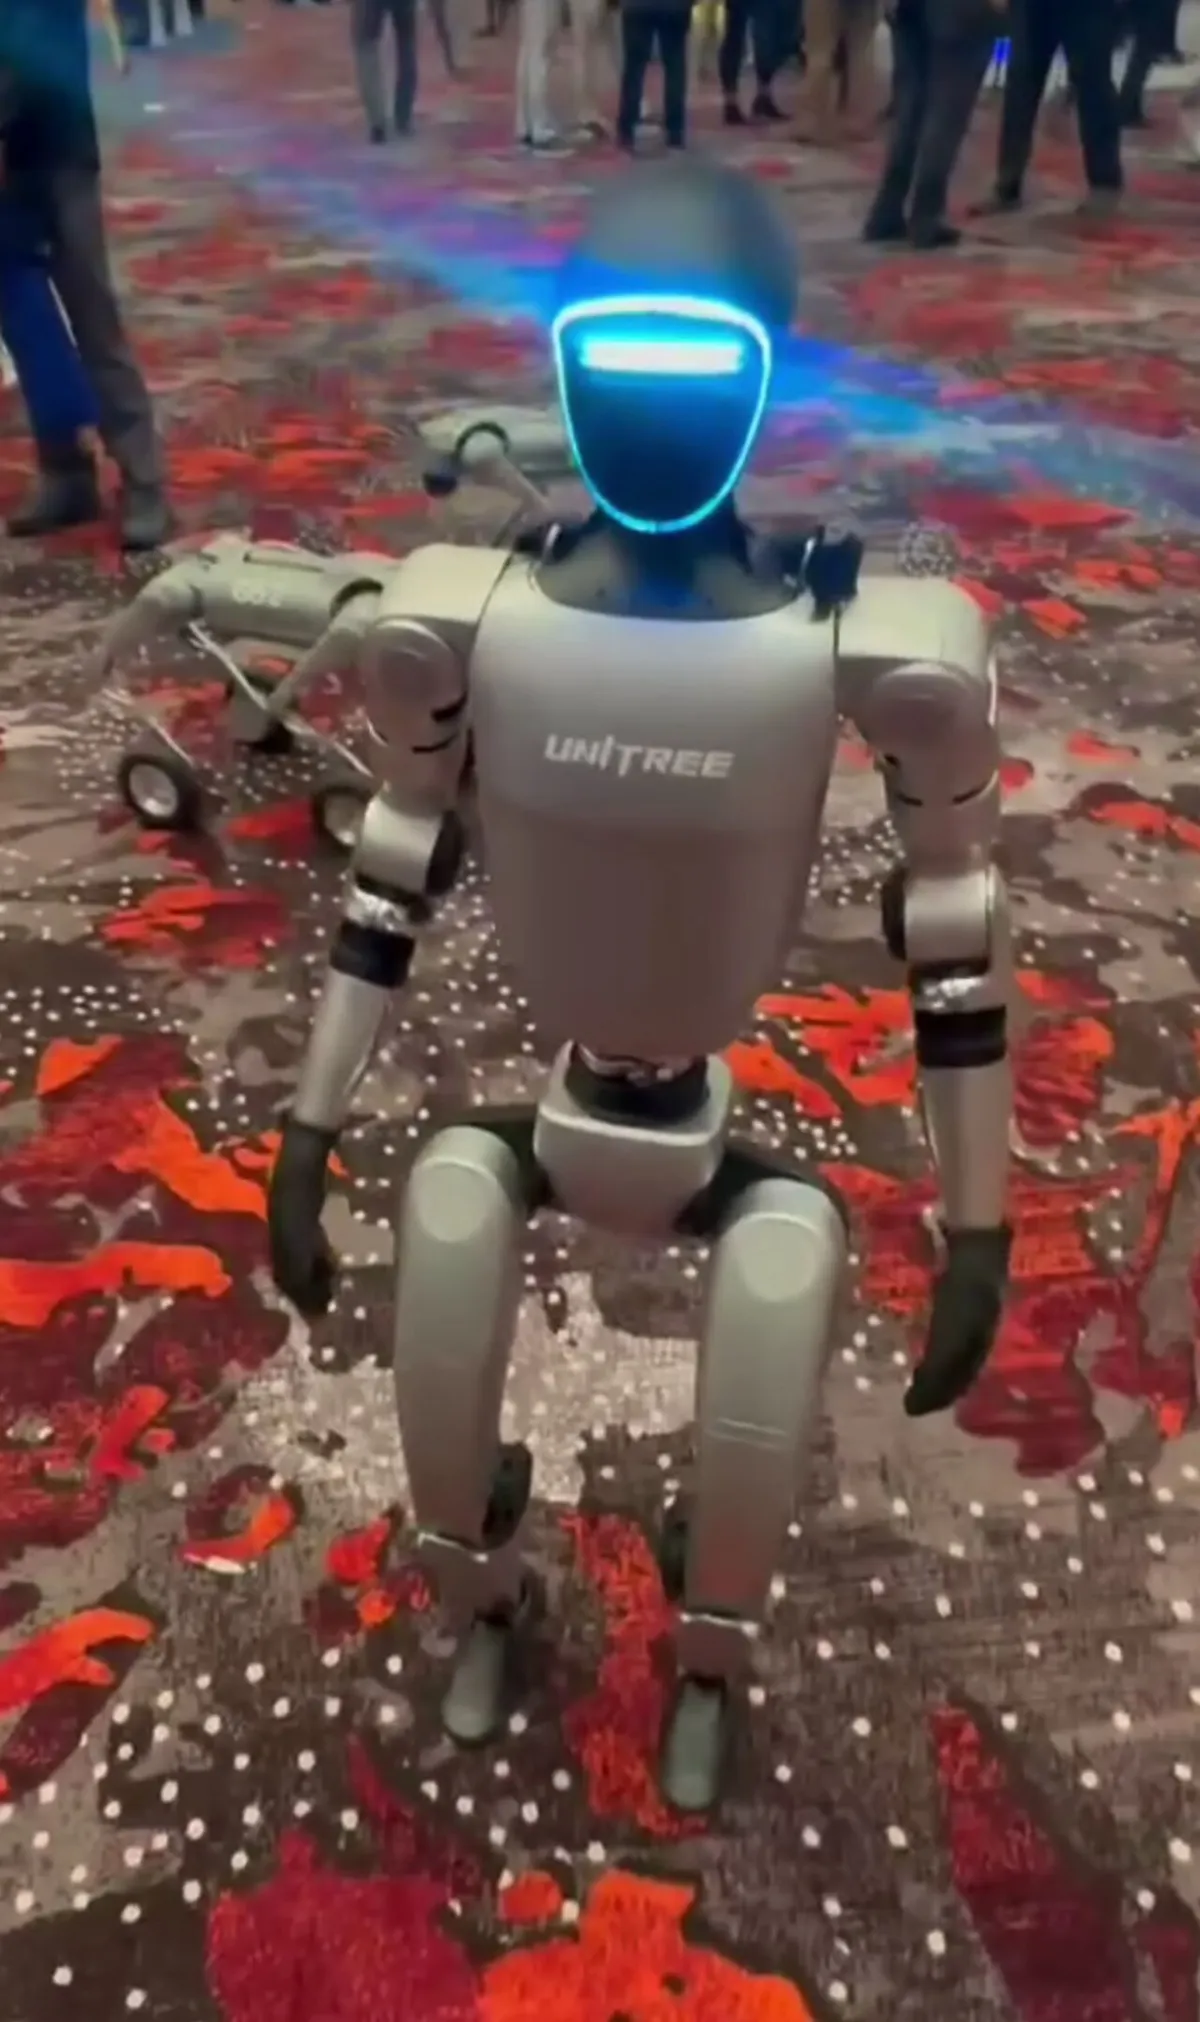 China
Humanoids & R&D
Unitree G1
Bipedal humanoid
Payload
2 kgRuntime
2 hSpeed
7.2 km/h$13,500 – $16,000price as of September 2026
On salePhoto coming soon
ChinaHumanoids & R&D
Unitree H1
Bipedal humanoid
Payload
7 kgRuntime
no dataSpeed
no data$90,000price as of September 2026
Made to orderPhoto coming soon
USAHumanoids & R&D
Figure 02
Bipedal humanoid
Payload
20 kgRuntime
5 hSpeed
3 km/hNot for sale, no price
Not for sale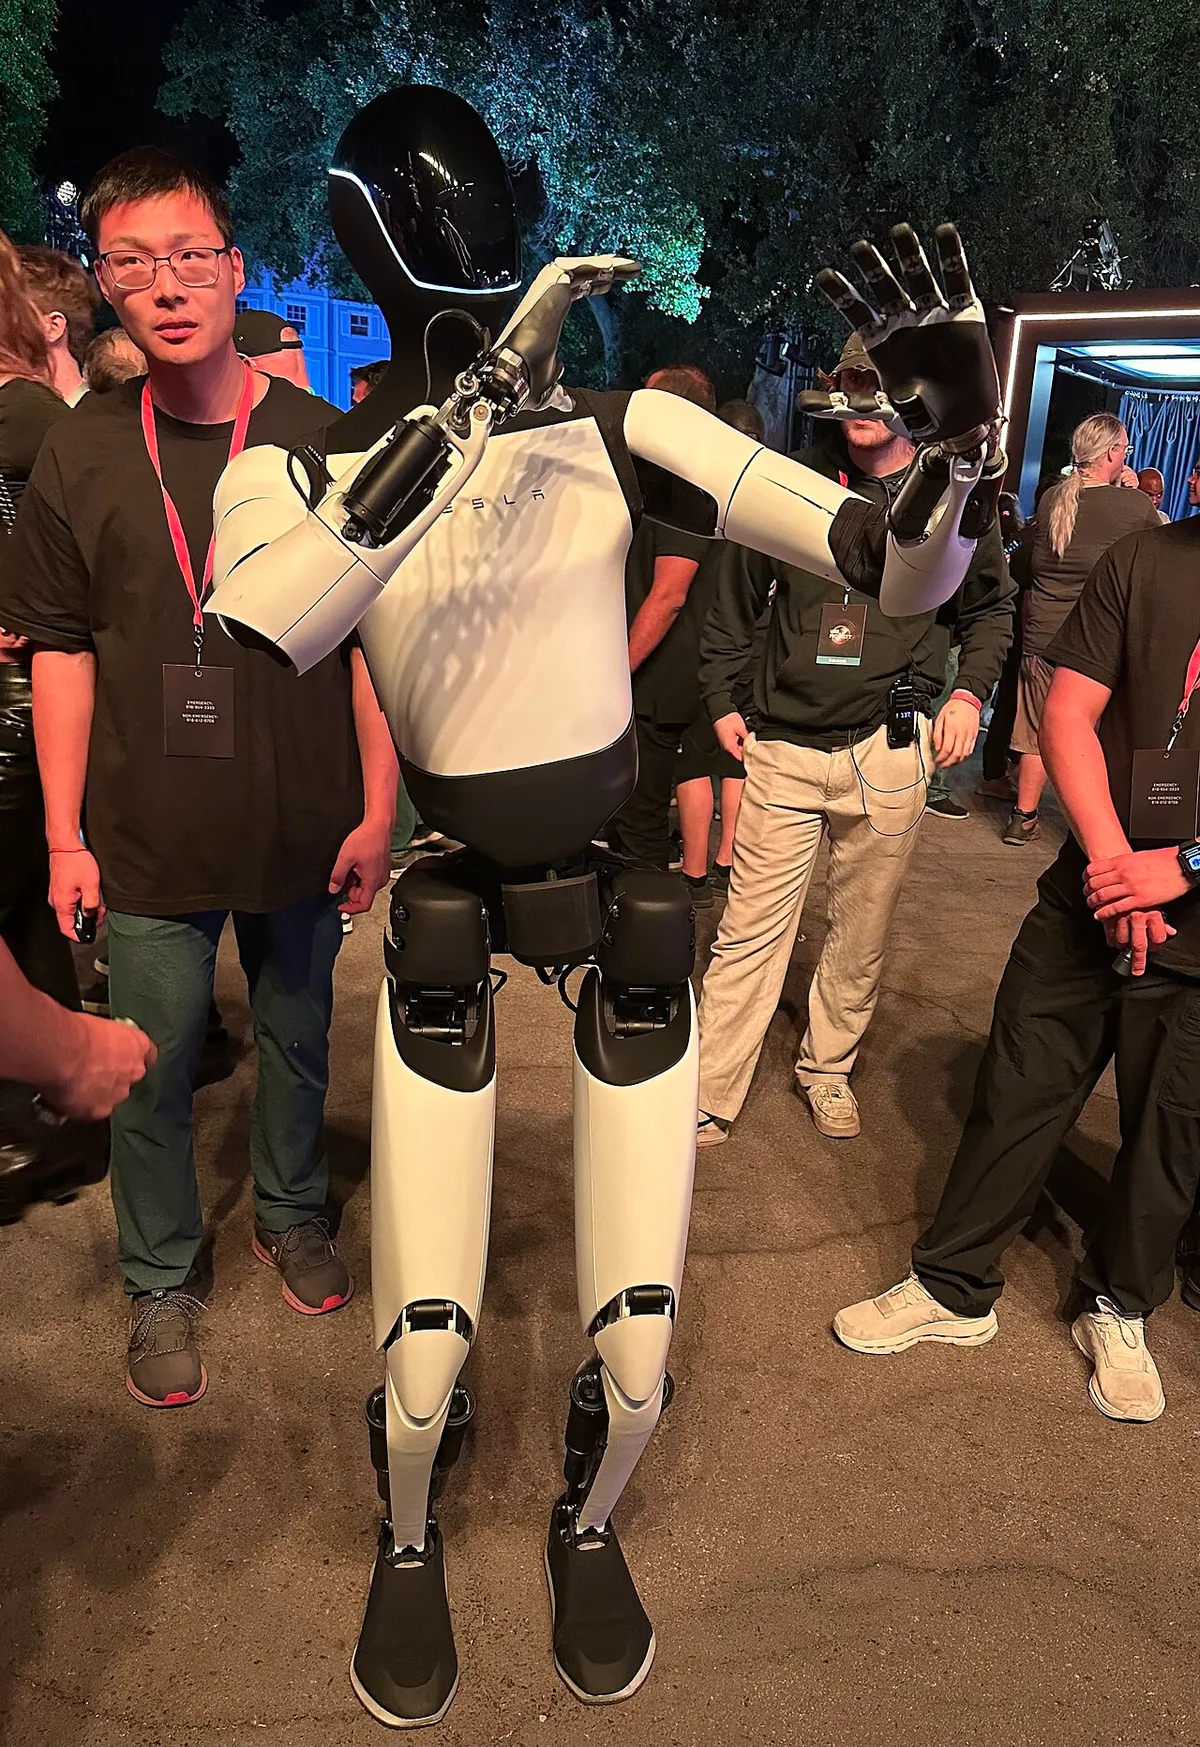 USA
Humanoids & R&D
Tesla Optimus
Bipedal humanoid
Payload
no dataRuntime
no dataSpeed
no dataNot for sale, no price
Not for sale