Tactile sensor
A sensor that detects touch and pressure on a robot finger or skin.
Cameras show where an object is, but only touch tells the robot whether it is slipping or whether it is squeezing too hard. With tactile sensing a hand can hold an egg, a paper cup or a wet glass without a single preprogrammed force value.
This feature is mostly present on advanced research and humanoid hands. For a buyer it matters when the robot must handle fragile or slippery items, or when it works next to people and should feel contact. Ask whether the sensors are on all fingers and how they are protected from wear.
Related terms
 China
Humanoids & R&D
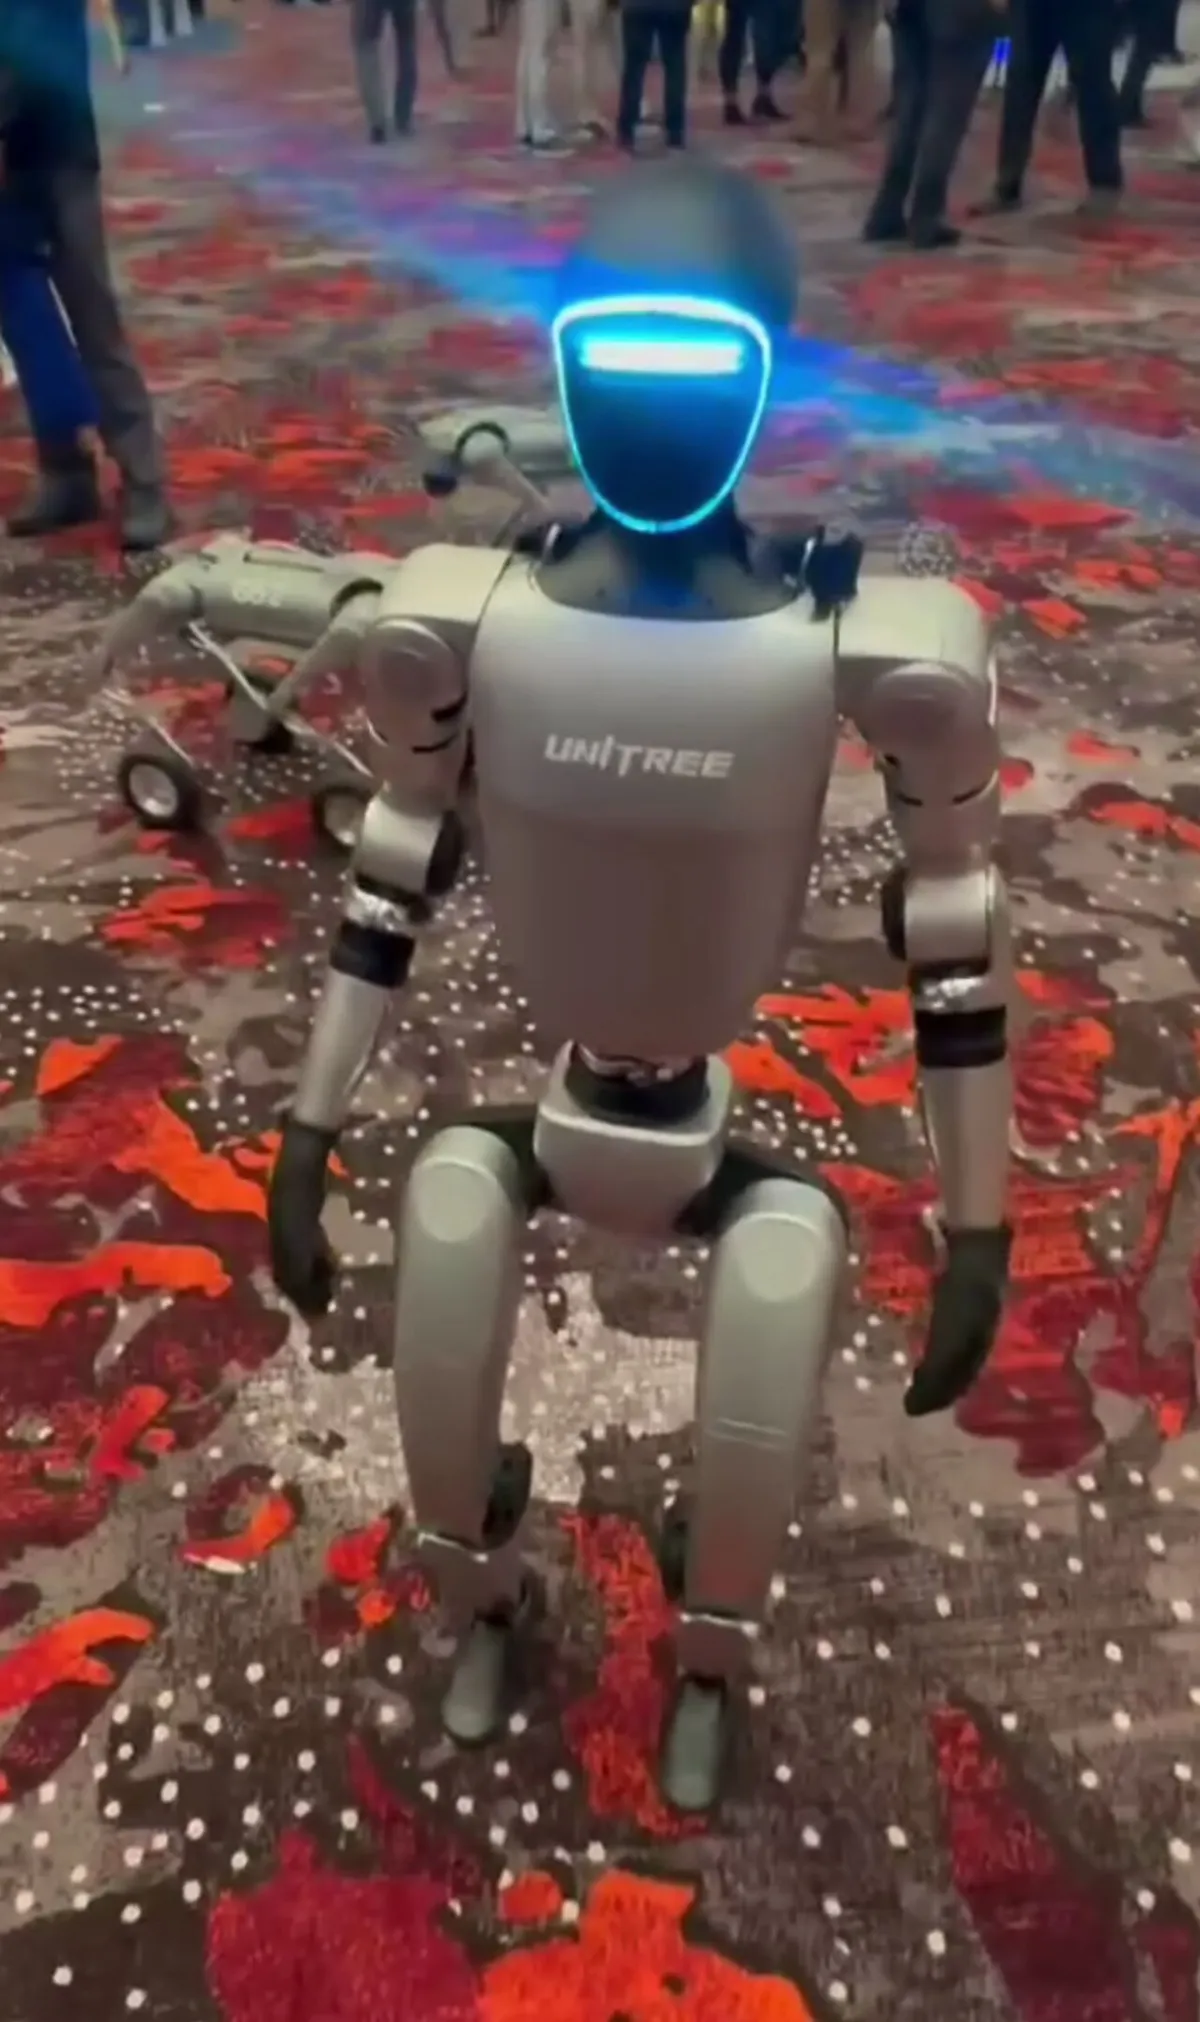
Unitree G1
Bipedal humanoid
Payload
2 kgRuntime
2 hSpeed
7.2 km/h$13,500 – $16,000price as of September 2026
On salePhoto coming soon
ChinaHumanoids & R&D
Unitree H1
Bipedal humanoid
Payload
7 kgRuntime
no dataSpeed
no data$90,000price as of September 2026
Made to orderPhoto coming soon
USAHumanoids & R&D
Figure 02
Bipedal humanoid
Payload
20 kgRuntime
5 hSpeed
3 km/hNot for sale, no price
Not for sale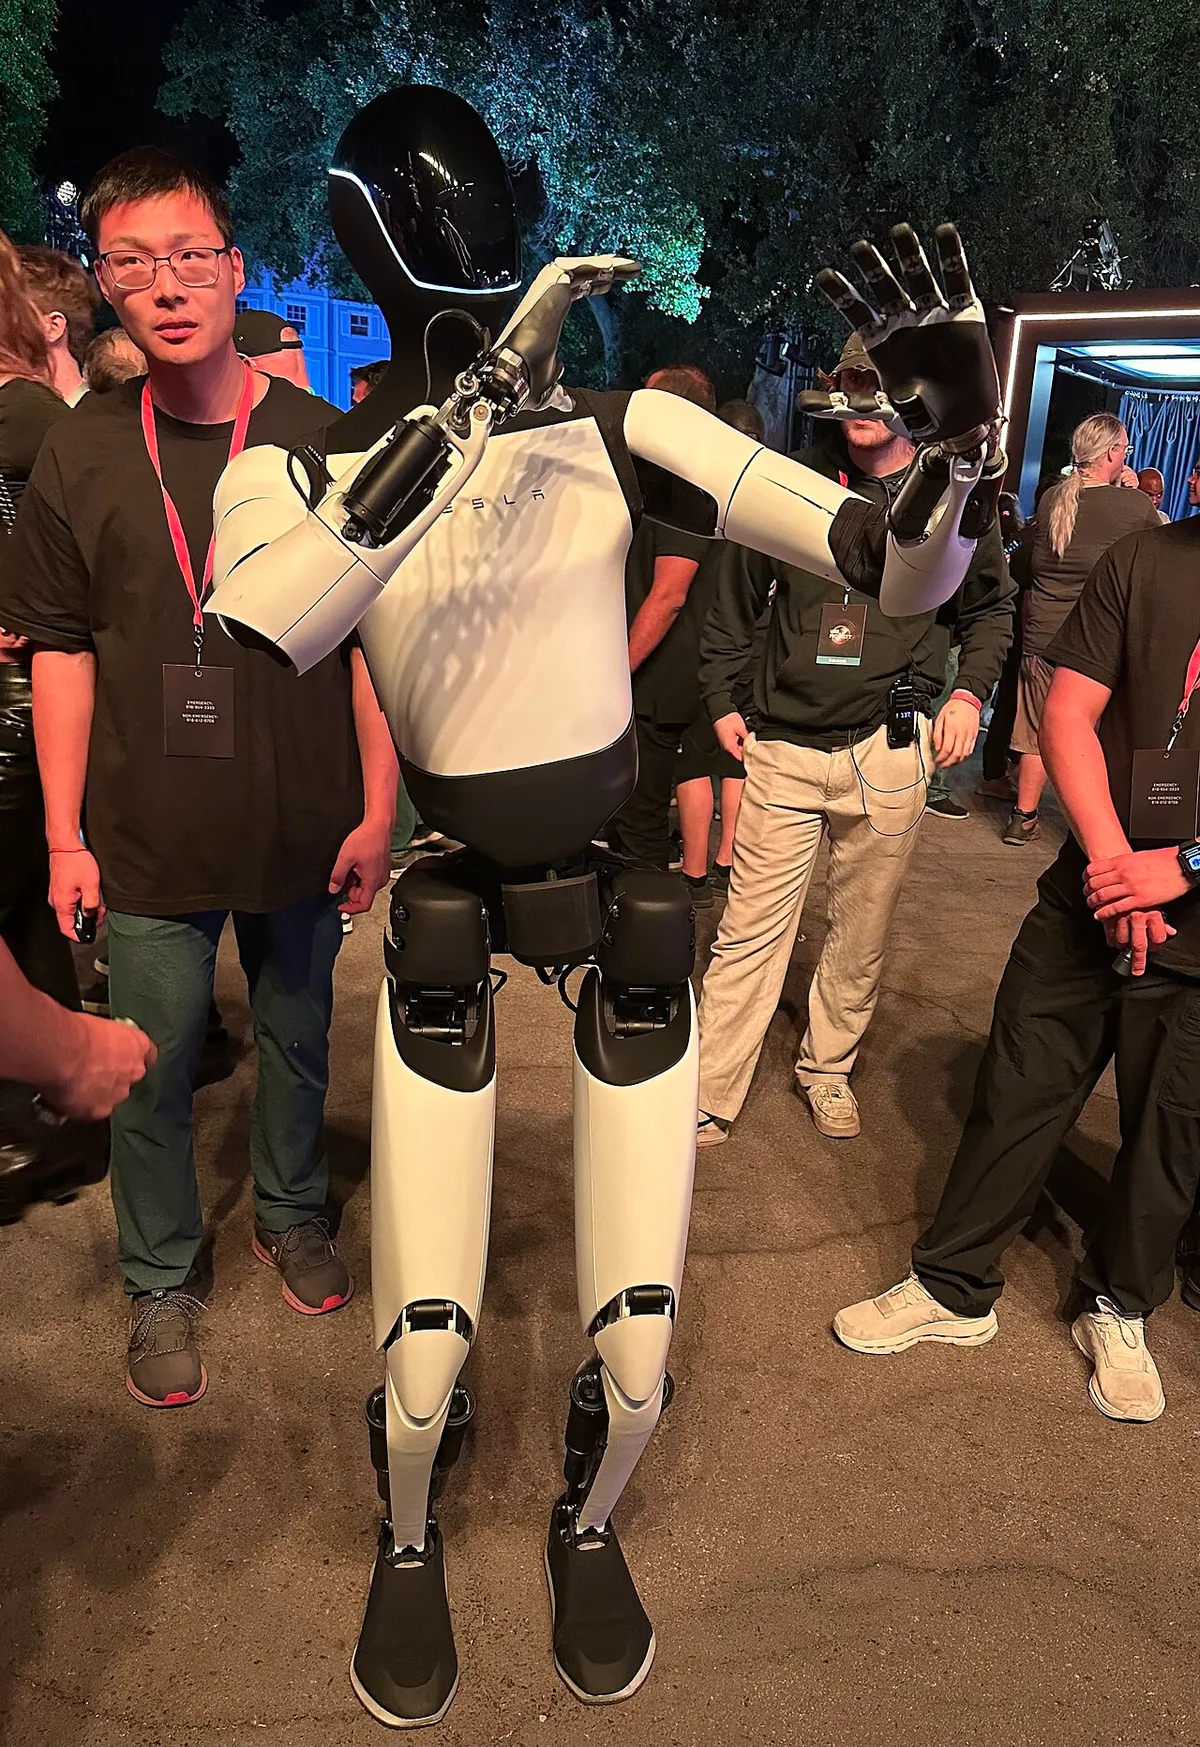 USA
Humanoids & R&D
Tesla Optimus
Bipedal humanoid
Payload
no dataRuntime
no dataSpeed
no dataNot for sale, no price
Not for sale