Dexterous hand
A multi-fingered robot hand with many degrees of freedom for fine manipulation.
A simple two-finger gripper picks up boxes. A dexterous hand with five fingers and 12 to 24 DOF can turn a screwdriver, press buttons, handle a phone or hold a pen. Hands are widely seen as one of the hardest parts of humanoid robotics, because they need to be small, strong and sensitive at the same time.
If your task is boxes and bags, you do not need one and a simple gripper will be cheaper and more reliable. If you need human-like tool use, check the number of active DOF (not just joints), fingertip force, tactile sensing and how often the hand needs service.
Related terms
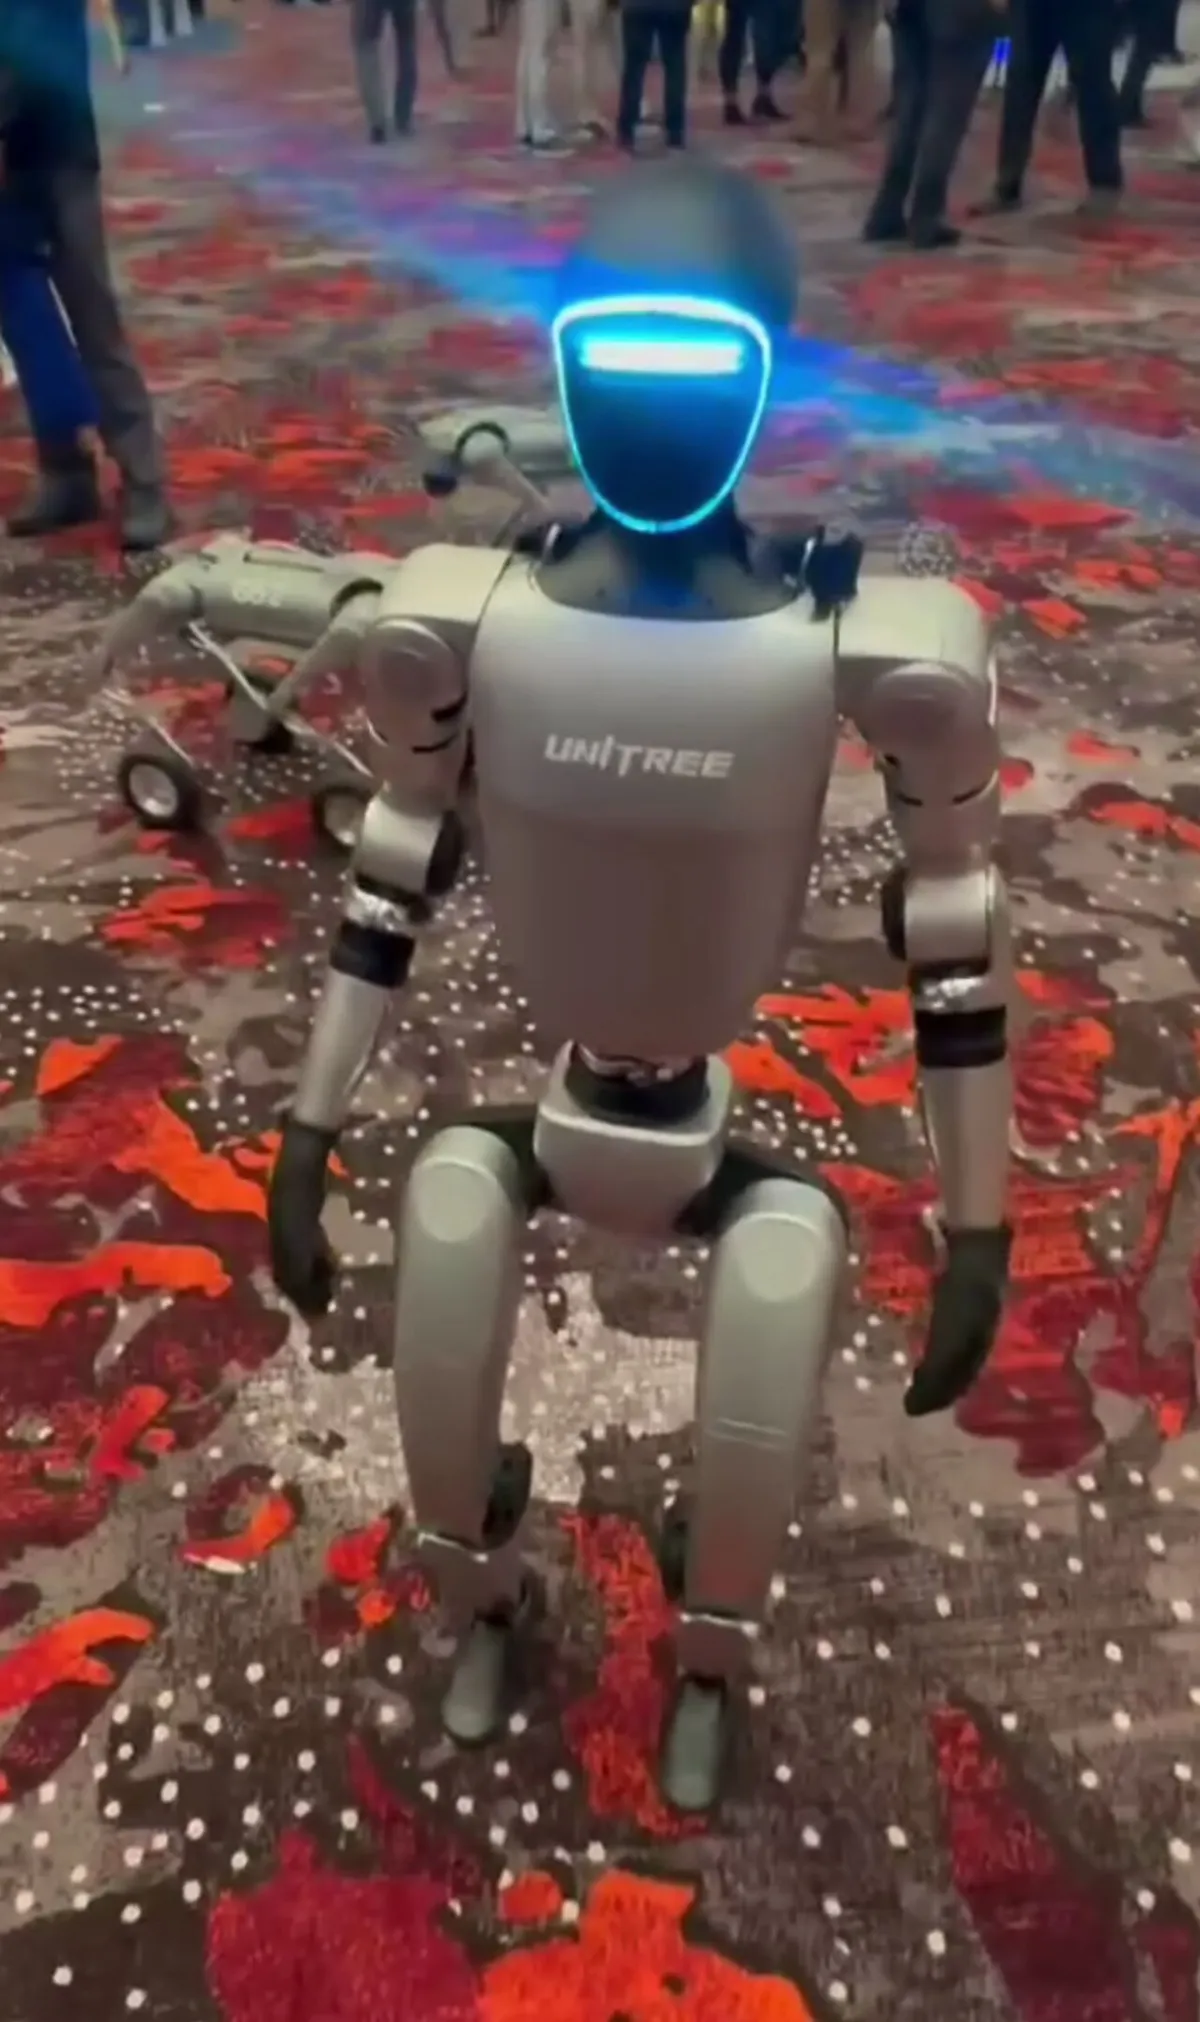 China
Humanoids & R&D
Unitree G1
Bipedal humanoid
Payload
2 kgRuntime
2 hSpeed
7.2 km/h$13,500 – $16,000price as of September 2026
On salePhoto coming soon
ChinaHumanoids & R&D
Unitree H1
Bipedal humanoid
Payload
7 kgRuntime
no dataSpeed
no data$90,000price as of September 2026
Made to orderPhoto coming soon
USAHumanoids & R&D
Figure 02
Bipedal humanoid
Payload
20 kgRuntime
5 hSpeed
3 km/hNot for sale, no price
Not for sale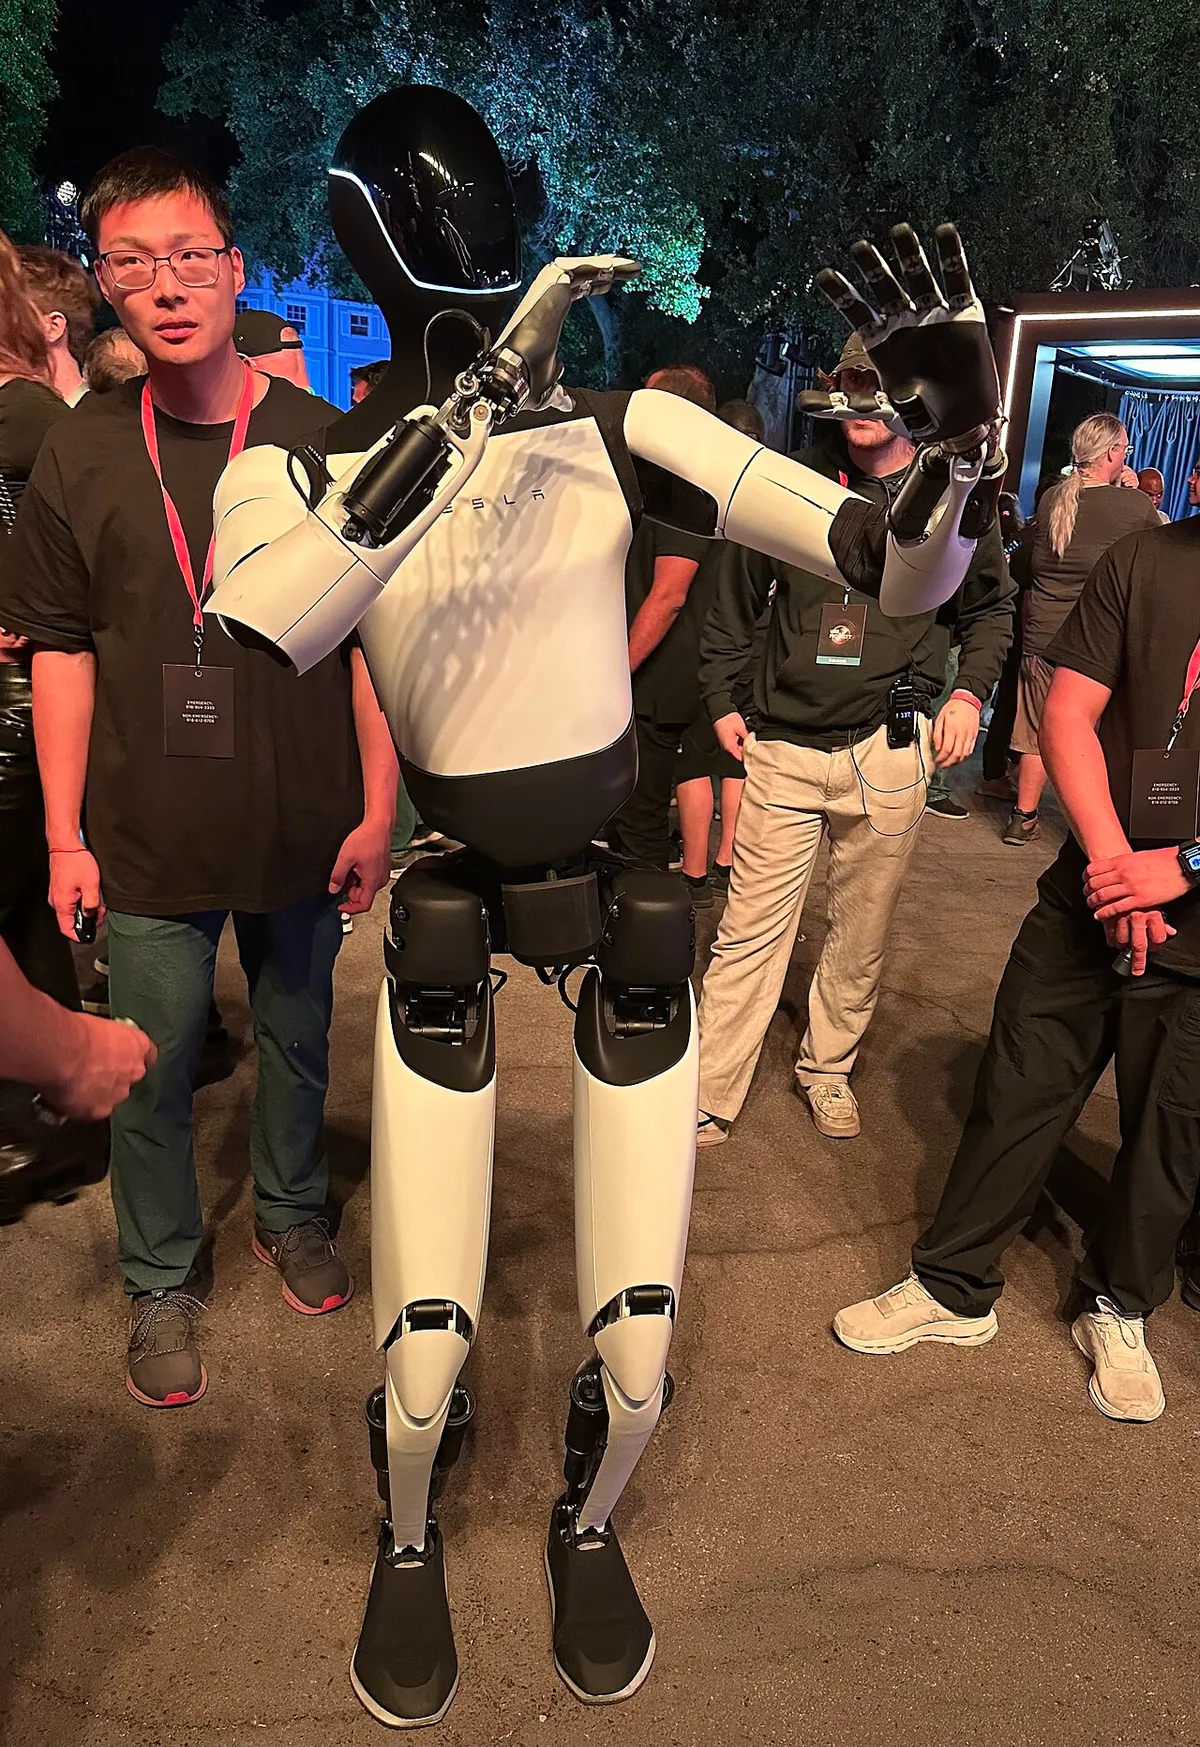 USA
Humanoids & R&D
Tesla Optimus
Bipedal humanoid
Payload
no dataRuntime
no dataSpeed
no dataNot for sale, no price
Not for sale