ROS / ROS 2
An open-source framework of tools and libraries for programming robots.
ROS (Robot Operating System) is not an operating system but a set of ready-made components for navigation, perception, arm control and simulation, with a common way for them to exchange messages. ROS 2 is the current generation, built for commercial and real-time use.
If a robot supports ROS 2, you can use a large body of existing software and hire people who already know it. For education and research this is nearly a requirement. For a restaurant owner it is mostly irrelevant, but it signals that the vendor does not lock you into a closed system.
Related terms
 China
Humanoids & R&D
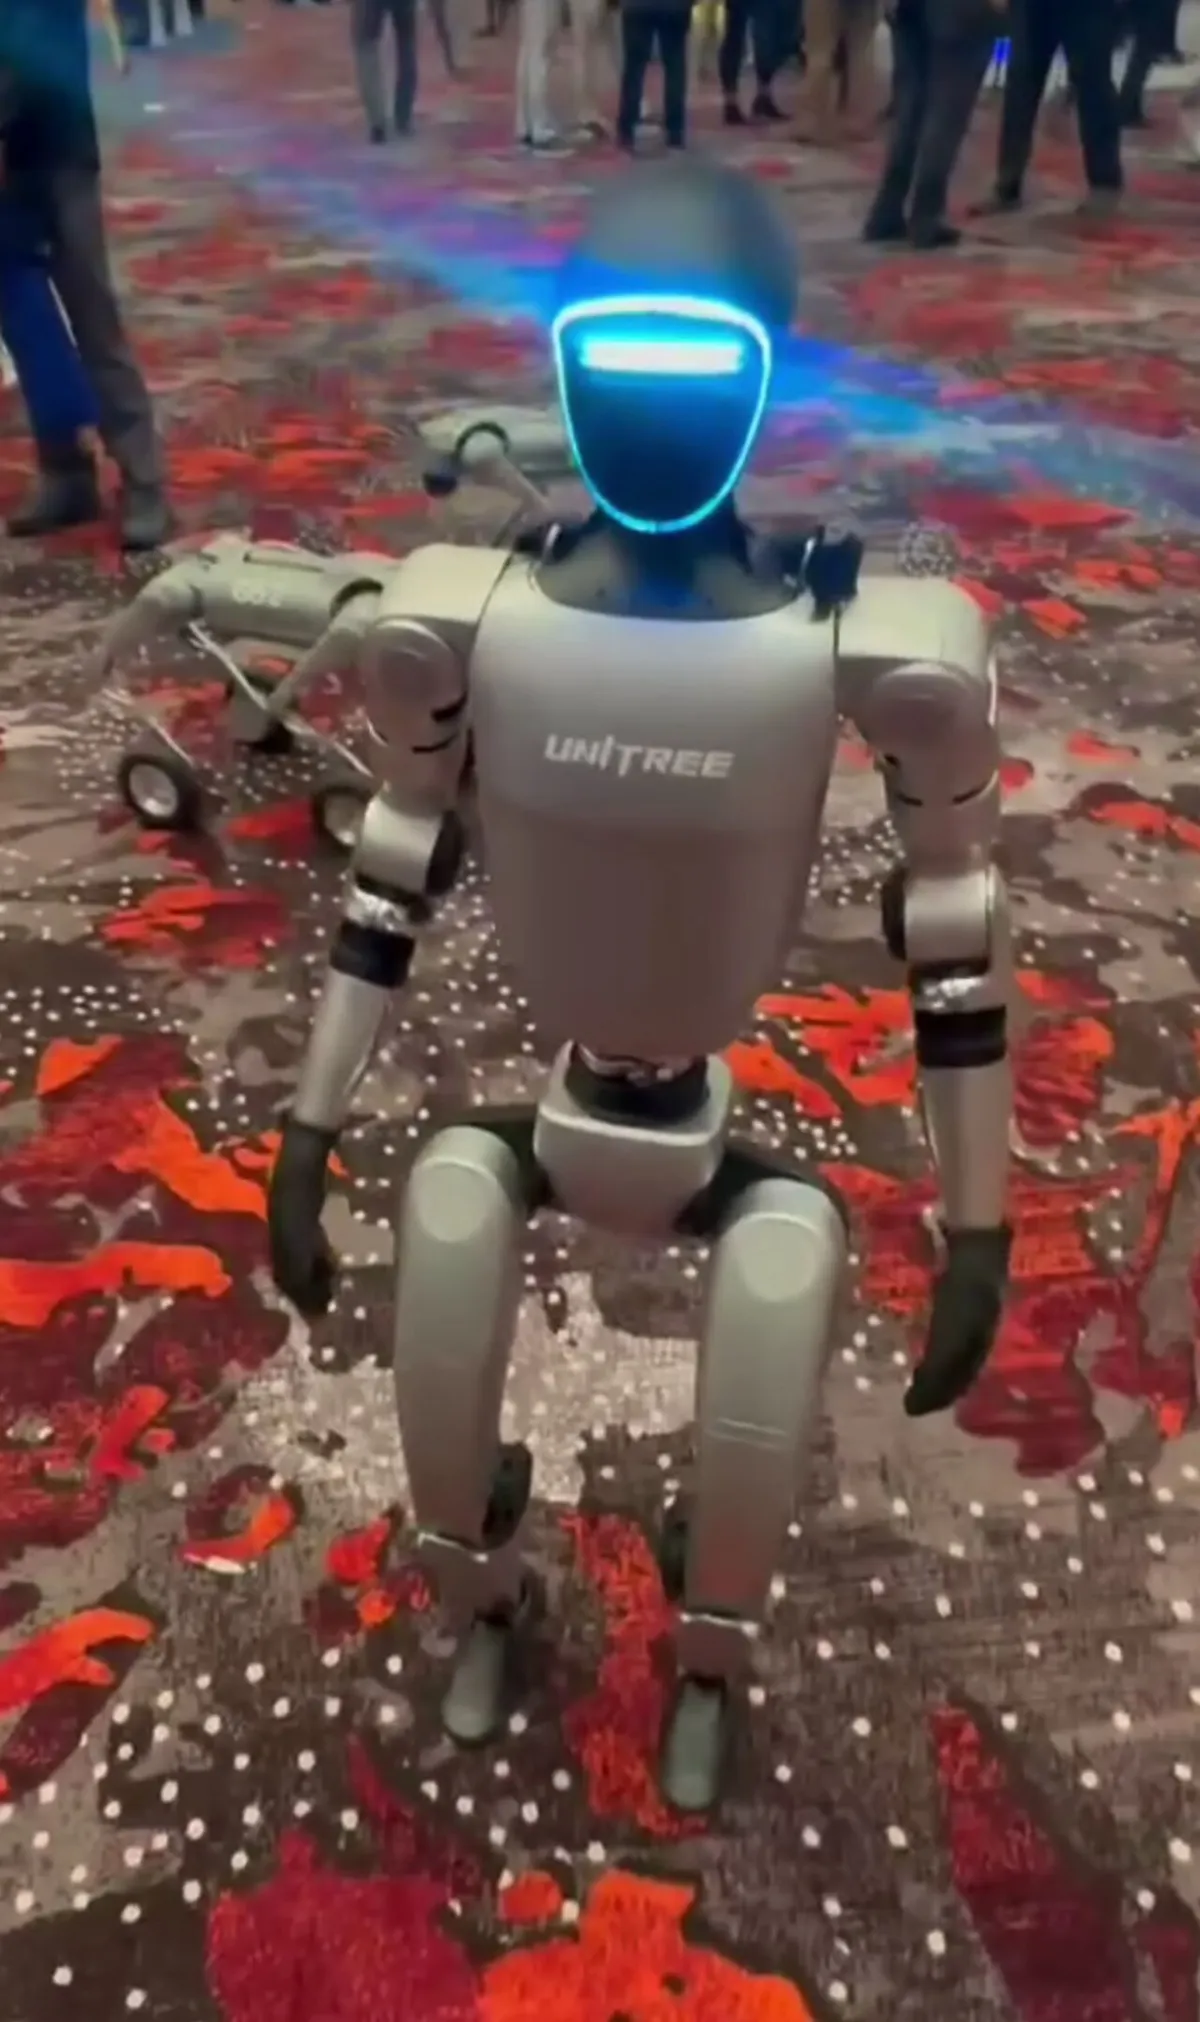
Unitree G1
Bipedal humanoid
Payload
2 kgRuntime
2 hSpeed
7.2 km/h$13,500 – $16,000price as of September 2026
On salePhoto coming soon
ChinaHumanoids & R&D
Unitree H1
Bipedal humanoid
Payload
7 kgRuntime
no dataSpeed
no data$90,000price as of September 2026
Made to orderPhoto coming soon
USAHumanoids & R&D
Figure 02
Bipedal humanoid
Payload
20 kgRuntime
5 hSpeed
3 km/hNot for sale, no price
Not for sale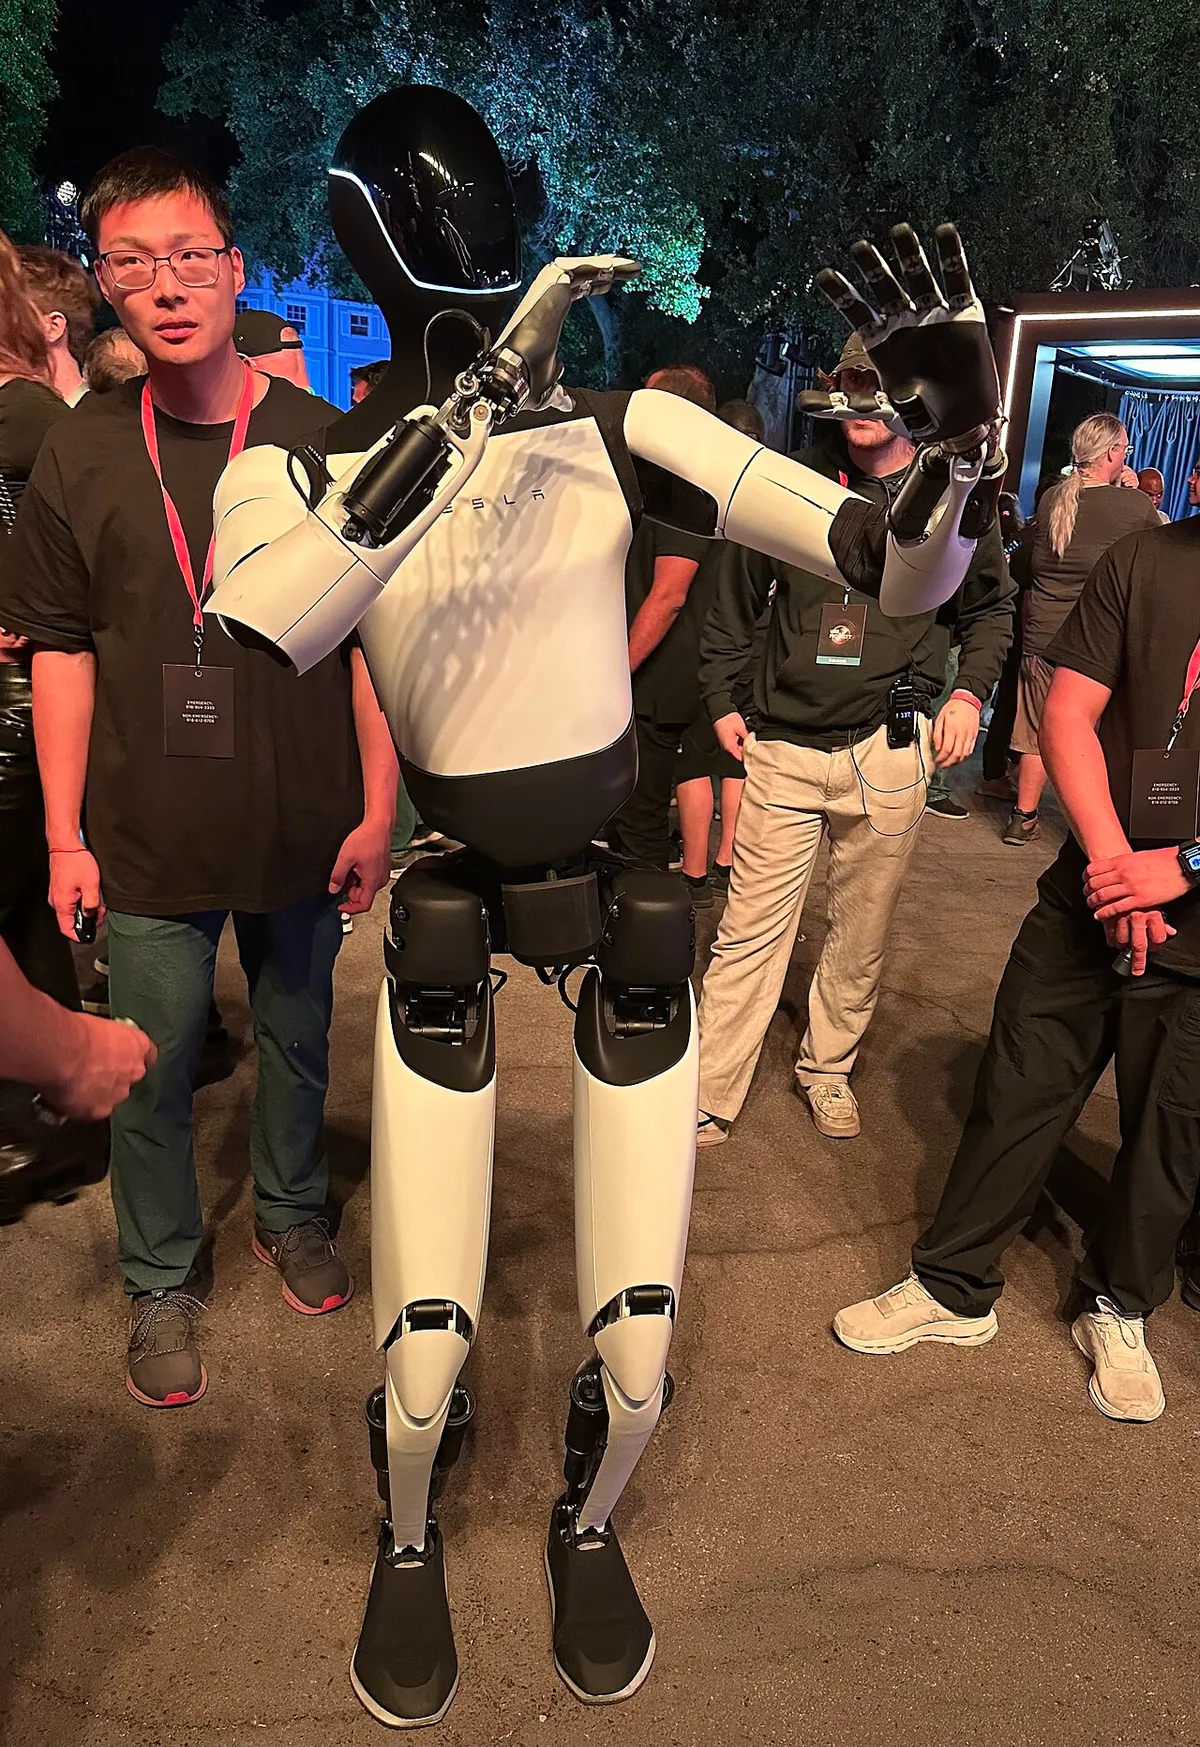 USA
Humanoids & R&D
Tesla Optimus
Bipedal humanoid
Payload
no dataRuntime
no dataSpeed
no dataNot for sale, no price
Not for sale